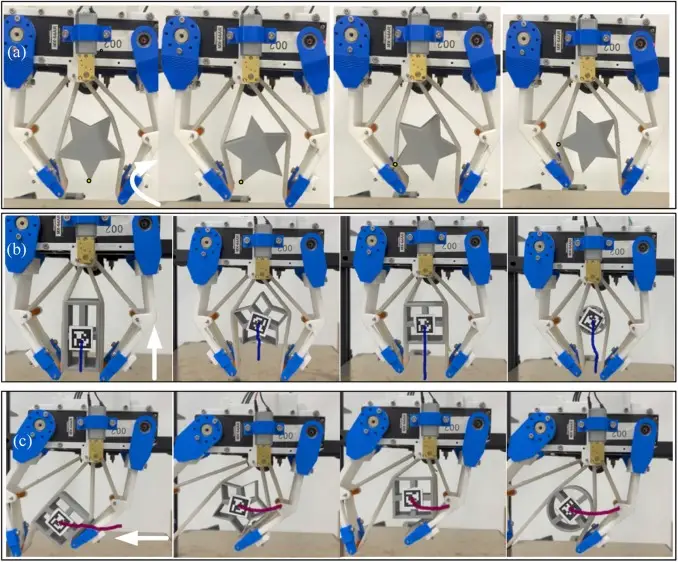
项目概述
手内操作的稳定性是机器人抓取与操控领域的核心需求,针对传统夹持器难以适配不规则外形物体、夹持力控制精度不足、易出现物体滑脱等问题,本项目提出一种基于自适应包裹与主动弹性带的夹持器设计方案。该夹持器融合自适应包裹机制与主动弹性带驱动结构,可根据被夹持物体的外形特征自动调整包裹形态,通过弹性带的主动伸缩实现夹持力的柔性调控,有效提升不规则、易损物体手内操作的稳定性与安全性,为机器人手内操作技术的优化提供了新的思路与实践参考,可广泛应用于工业装配、医疗辅助、精密制造等领域。
个人负责工作
本人全程参与项目核心研发工作,具体负责内容如下:
机械结构设计:负责设计抓手的机械结构,重点完成手指骨架、电机支座的设计与优化,确保结构的刚性、轻量化及装配便捷性,适配弹性带驱动与自适应包裹功能。
硅胶带工艺研究与制备:开展硅胶带制备工艺研发,包括硅胶模具的设计、加工与调试,优化硅胶除泡工艺,解决硅胶带成型过程中的气泡、尺寸偏差等问题,保障硅胶带的柔性与耐用性。
控制程序编写:编写抓手全套控制程序,基于Simulink平台,实现对四个电机的精准控制,通过RS485通信协议完成电机指令传输、转速与力矩调节,确保夹持动作的平稳性与可控性。
数学建模与仿真测试:对抓手整体结构进行数学建模与理论分析,明确夹持力与弹性带伸缩量、电机转速的关联关系;使用ABAQUS软件对柔性硅胶带进行仿真测试,验证硅胶带的受力特性、形变规律,为结构优化提供理论支撑。
实验测试设计与实施:设计针对性的实验方案,搭建实验测试平台,对抓手的抓取性能、操控稳定性、适配性等核心指标进行全面测试,记录实验数据并进行分析优化,确保项目达到预设设计目标。
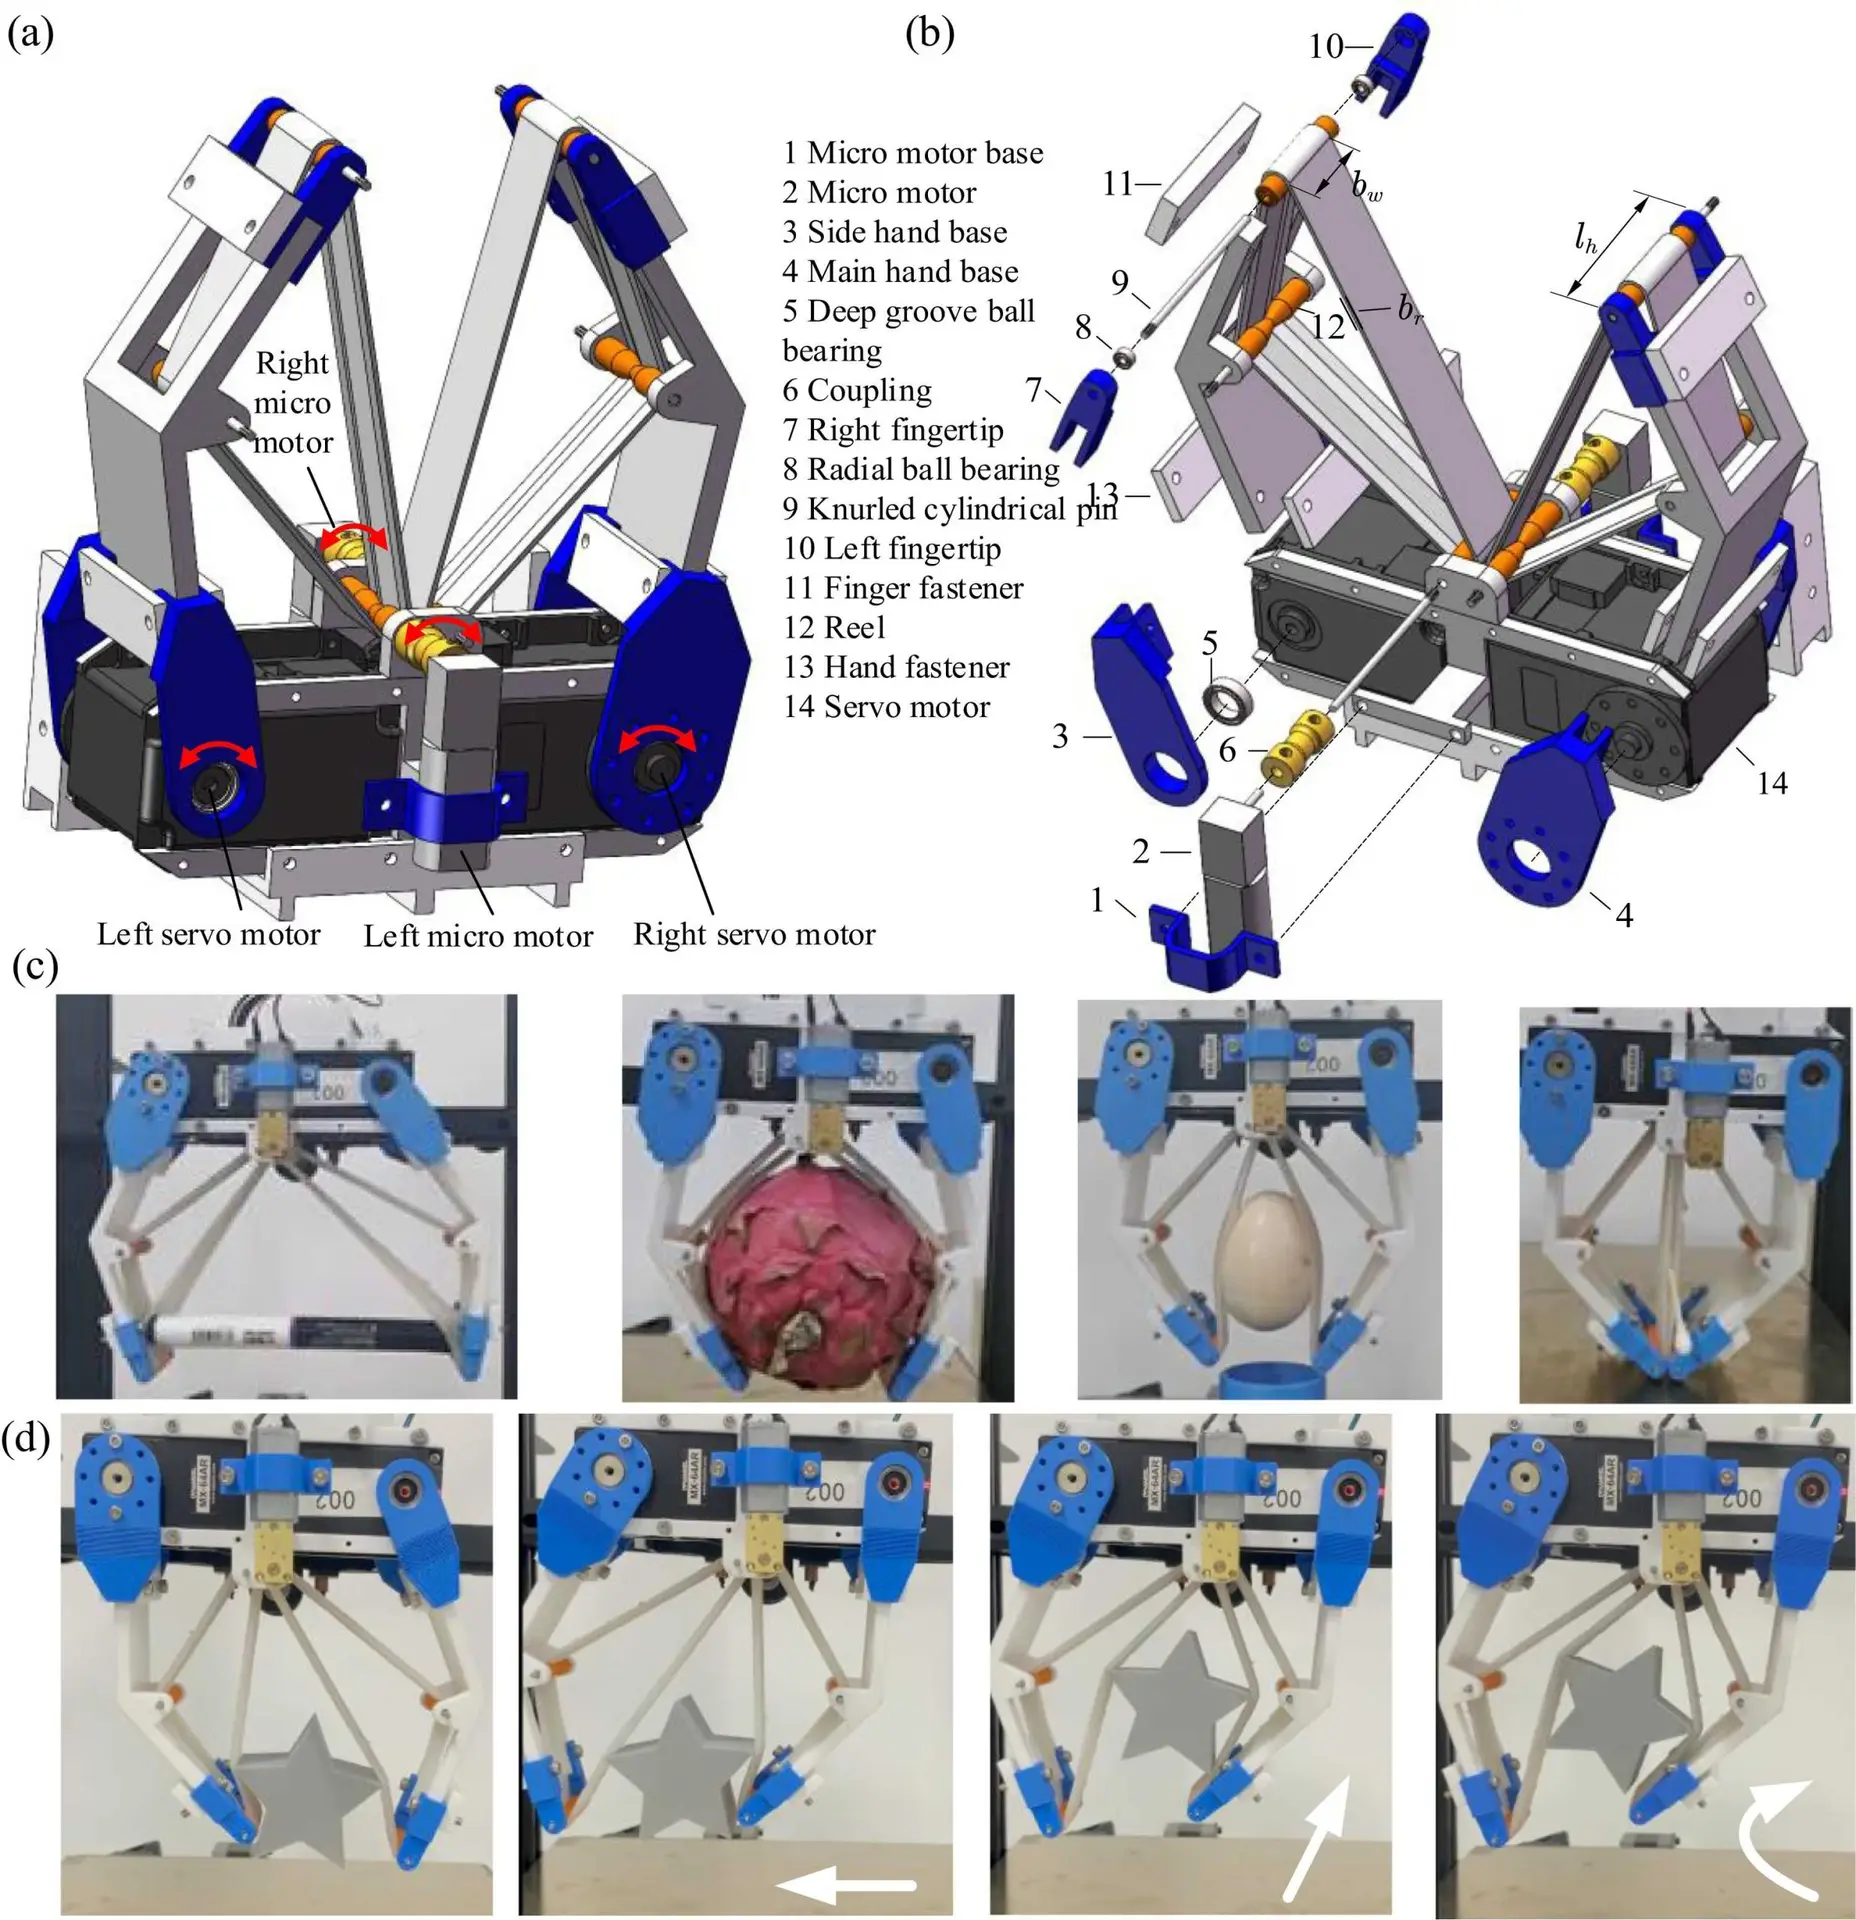
项目成果
论文发表:项目相关研究成果发表于核心期刊《Sensors and Actuators: A. Physical》,论文题目为《Adaptive Wrapping with Active Elastic Band-based Gripper for Stable In-Hand Manipulation》,系统阐述了夹持器的设计原理、实验过程与研究结论。
发明专利:获得国家发明专利1项,专利名称:基于弹性带自适应包裹的双指操控手及其抓取力估计方法,专利号:CN202311690679.7,保护项目核心技术创新点。
实物与演示:完成抓手实物制作与调试,可稳定实现不规则物体的抓取、搬运及细微操控任务;配套项目演示视频,直观展示抓手的工作流程、自适应包裹效果及操控稳定性。